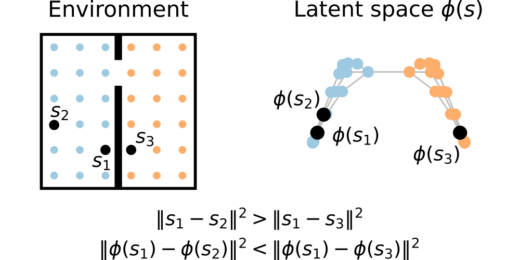
New paper led by Michael Hauri & Peter Buttaroni: “Learning Commute-Time-Preserving World Models for Planning.” We show how to shape a world model’s latent space so its distances mean something for planning. 📄 https://arxiv.org/abs/2610.01373 💻 https://github.com/fmi-basel/commute-time-preserving-world-models 🌐Continue reading
Tag: michael
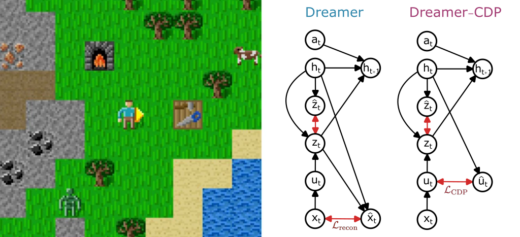
New paper: Dreamer-CDP — Reconstruction-Free World Models for Reinforcement Learning
In our new tiny paper accepted at the ICLR workshop on world models we introduce Dreamer-CDP, a Dreamer variant that learns a world model without reconstructing raw pixel observations. Preprint: https://arxiv.org/abs/2603.07083 Standard model-based reinforcement learningContinue reading
New mates on our crew
This year we gladly welcome four new Kraken Crew members: Fabian, Thomas, Michael, and Rory (jointly with the Friedrich lab). We look forward to what we will learn from your cool research projects and toContinue reading